
2 posts tagged with "rosbot"

View All Tags

New Husarion OS release for ROSbot 3/XL

· 7 min read
Rafal Gorecki
Software Developer @ Husarion

A new Husarion OS build (2026.09.30) is rolling out now. It's the biggest update to what ships out of the box since the last release in August 2025, and ROSbot 3 and ROSbot XL owners will feel it the most:

  • Husarion Cockpit adds a web panel for driving and managing the robot: teleop with a live camera view, ROS 2 configuration, and robot state at a glance, all from a phone or laptop.
  • Nav2 built into the rosbot snap means no separate demo repo to clone, so you can go from unboxing to autonomous navigation in minutes.
  • Ubuntu 24.04 support for Jetson: the latest Tegra/L4T kernel (39.2.1) moves the Jetson Orin image to an Ubuntu 24.04 base, which brings ROS 2 Jazzy natively.
  • The latest ROSbot drivers and snaps: this build ships on top of the latest rosbot_ros driver, so ROSbot's sensors pick up their ROS 2 config on their own. Set it once on the robot, and every chained LiDAR or camera follows. See the driver release post for namespaces, Zenoh, and the firmware rewrite.
  • A handful of smaller quality-of-life fixes: easier login without remembering an IP, full sensor integration out of the box, and more.
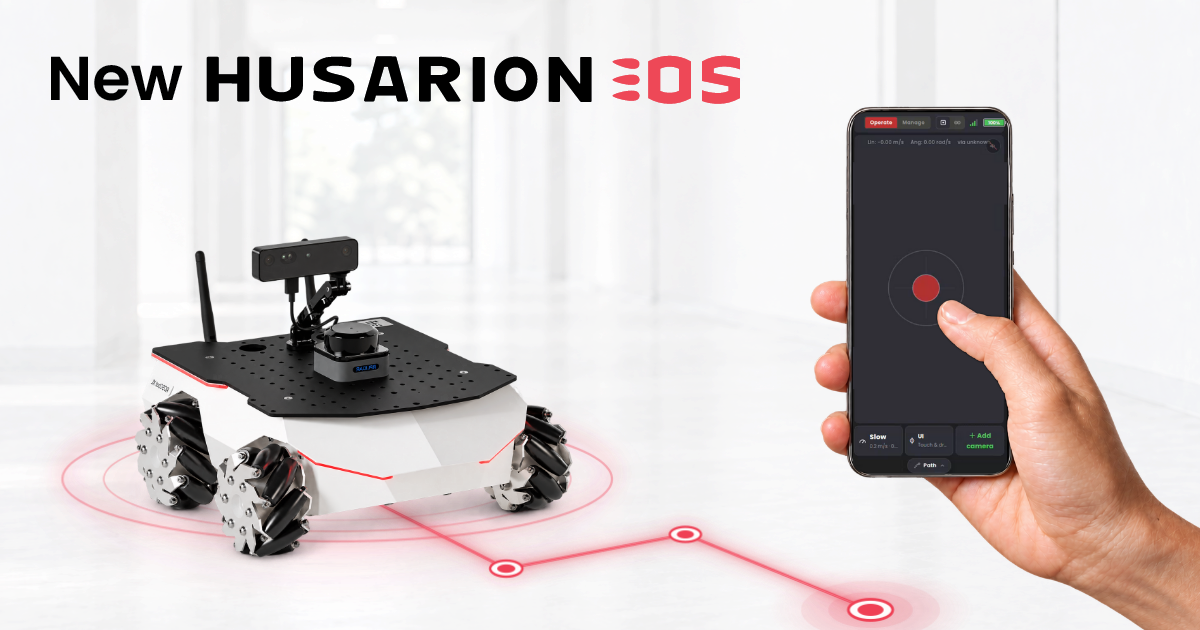
Husarion OS release title image

ROSbot ROS 2 driver v1.0.0 released!

· 14 min read
Rafal Gorecki
Software Developer @ Husarion

You leave your ROSbot on the desk, walk away to grab a coffee, and when you turn around you hear a faint whirr. The wheels are spinning, the robot is inching toward the edge of the table, and you catch it half a second before gravity does. Once your heart rate settles, one question stays stuck in your head: who just sent it /cmd_vel?

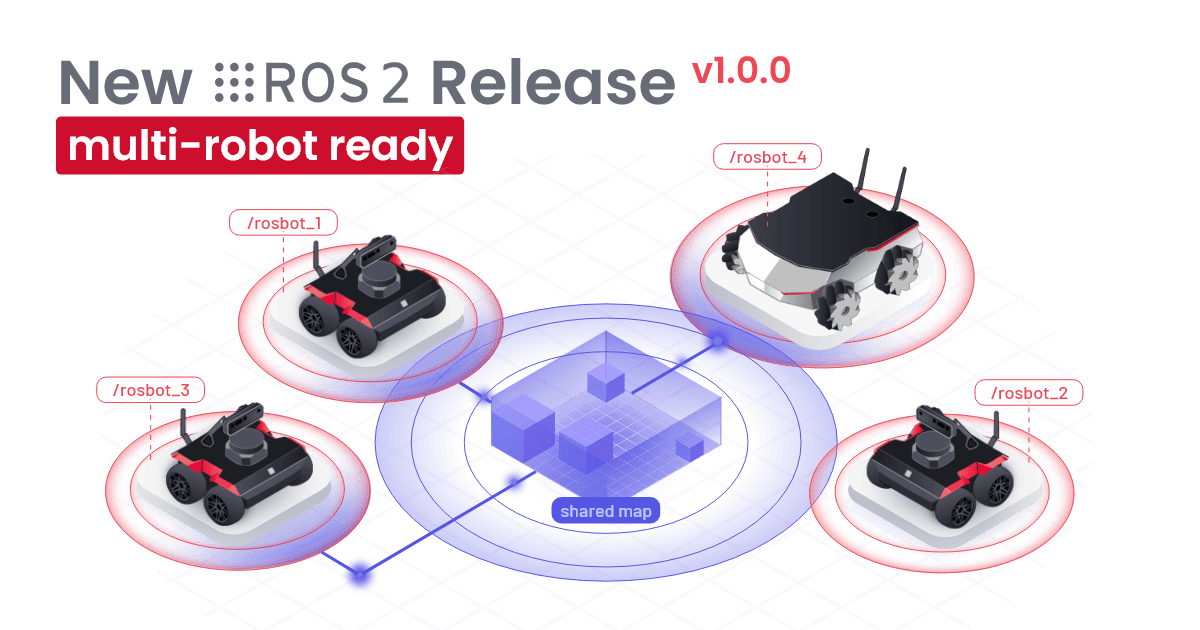
If you have ever shared a lab network with more than one ROSbot, you already know the answer: two robots listening on the same /cmd_vel, no namespaces to keep them apart, and whoever boots last wins. We have heard that story from users often enough, and lived it ourselves a few times, that fixing it became one of the headline goals for this release.

Today we are shipping ROSbot ROS v1.0.0, the first stable, unified release of the ROSbot software stack, covering both ROSbot 3 and ROSbot XL. Highlights:

  • Full ROS 2 namespace support across the driver and the firmware.
  • Zenoh networking for fleets that need to scale beyond one robot on one Wi-Fi.
  • Shared ROS 2 config across your accessories: set the namespace, middleware, and domain once on the ROSbot, and it cascades to every chained Husarion snap.
  • Up to 10× higher sensor and control loop rates thanks to a firmware-wide scheduling rewrite.
  • A led_strip topic (ROSbot XL) that lets you drive the LED panel from your own ROS 2 node.
  • Cartesian gamepad control of the manipulator (ROSbot XL): command motion in the gripper's own frame instead of joint by joint.
  • One firmware repository for both ROSbot 3 and ROSbot XL.
  • A simpler project structure that makes it easier to plug in your own changes.

ROSbot ROS v1.0.0 release