New Husarion OS release for ROSbot 3/XL
· 7 min read

A new Husarion OS build (2026.09.30) is rolling out now. It's the biggest update to what ships out of the box since the last release in August 2025, and ROSbot 3 and ROSbot XL owners will feel it the most:
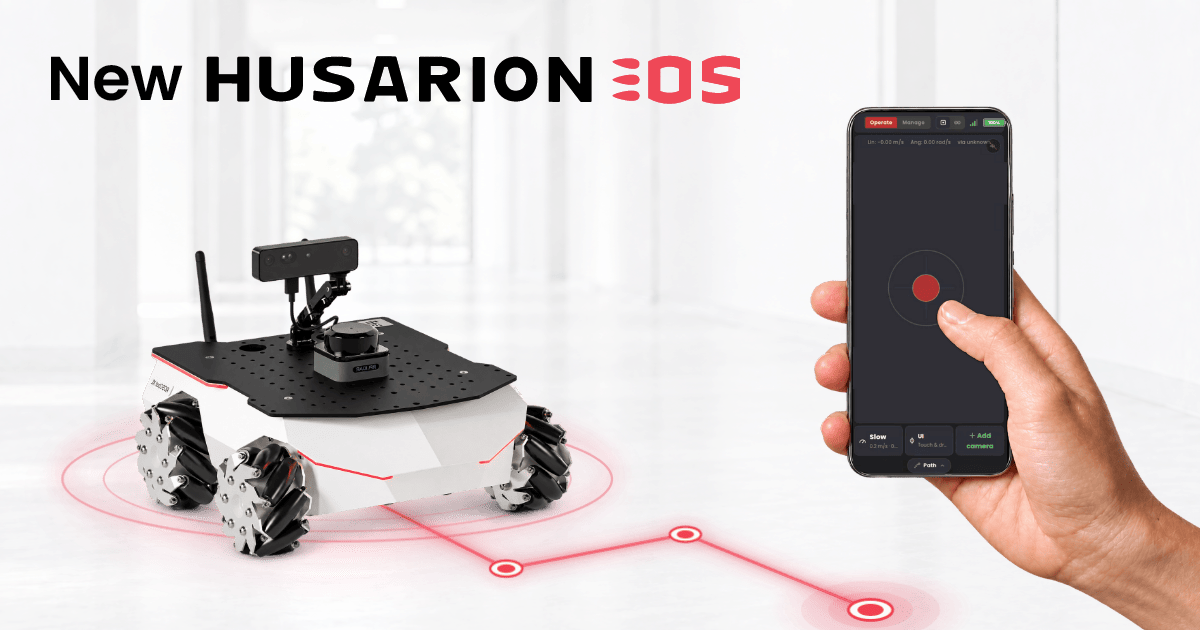
- Husarion Cockpit adds a web panel for driving and managing the robot: teleop with a live camera view, ROS 2 configuration, and robot state at a glance, all from a phone or laptop.
- Nav2 built into the
rosbotsnap means no separate demo repo to clone, so you can go from unboxing to autonomous navigation in minutes. - Ubuntu 24.04 support for Jetson: the latest Tegra/L4T kernel (
39.2.1) moves the Jetson Orin image to an Ubuntu 24.04 base, which brings ROS 2 Jazzy natively. - The latest ROSbot drivers and snaps: this build ships on top of the latest
rosbot_rosdriver, so ROSbot's sensors pick up their ROS 2 config on their own. Set it once on the robot, and every chained LiDAR or camera follows. See the driver release post for namespaces, Zenoh, and the firmware rewrite. - A handful of smaller quality-of-life fixes: easier login without remembering an IP, full sensor integration out of the box, and more.