ROSbot XL Configuration Packages
Each ROSbot XL mobile platform comes equipped with:
- A USB-C charger (65W)
- Two sets of wheels (4x regular and 4x mecanum).
The basic ROSbot XL package can be outfitted with a wide range of sensors and actuators available for purchase in our online store. For ease of use, we also provide a selection of pre-configured options. These configurations have been rigorously tested, and the software for them comes preinstalled in Husarion OS.
- Basic
- Telepresence
- Autonomy
- Manipulation
- Manipulation PRO
Basic Package
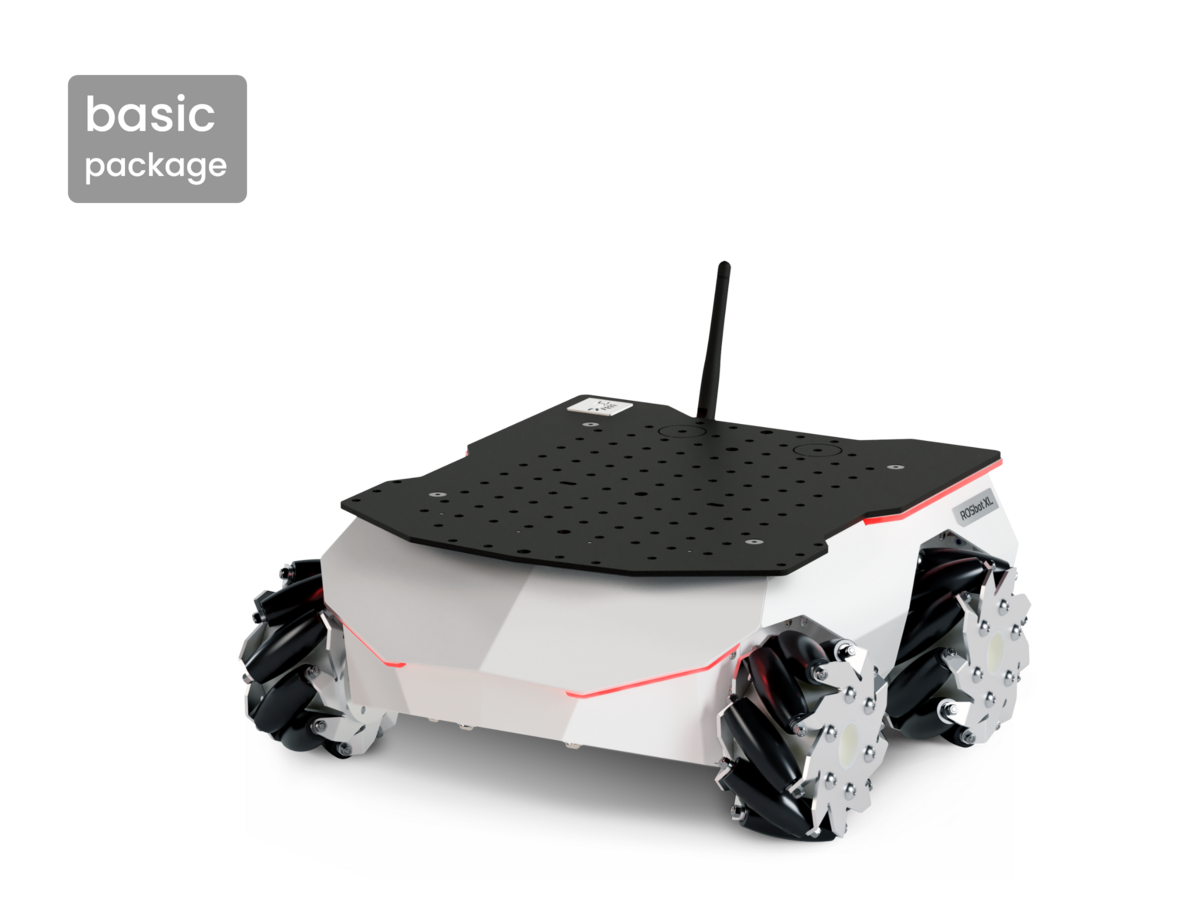
Select the basic package if you want just a ROSbot XL mobile platform with one of three computer options.
SBC Options
There are three different single board computer configurations in the Basic Package:
| Name | CPU architecture | CPU | RAM | GPU | Storage |
|---|---|---|---|---|---|
| Raspberry Pi 5 | ARM64 | ARM Cortex-A76 4 x 2.4 GHz | 8 GB | iGPU | 64 GB MicroSD |
| NVIDIA Jetson Orin Nano | ARM64 | ARM Cortex-A78AE 6 x 1.5 GHz | 8 GB | Nvidia Ampere 1024 CUDA cores 32 Tensor cores | 250 GB SSD |
| ASUS NUC (NUC14RVKi3) | x86-64 | Intel Core 3 100U 6 x 4.7 GHz | 16 GB | Intel® UHD Graphics | 250 GB SSD |
Additional Equipment
- Logitech F710 gamepad
Telepresence Package
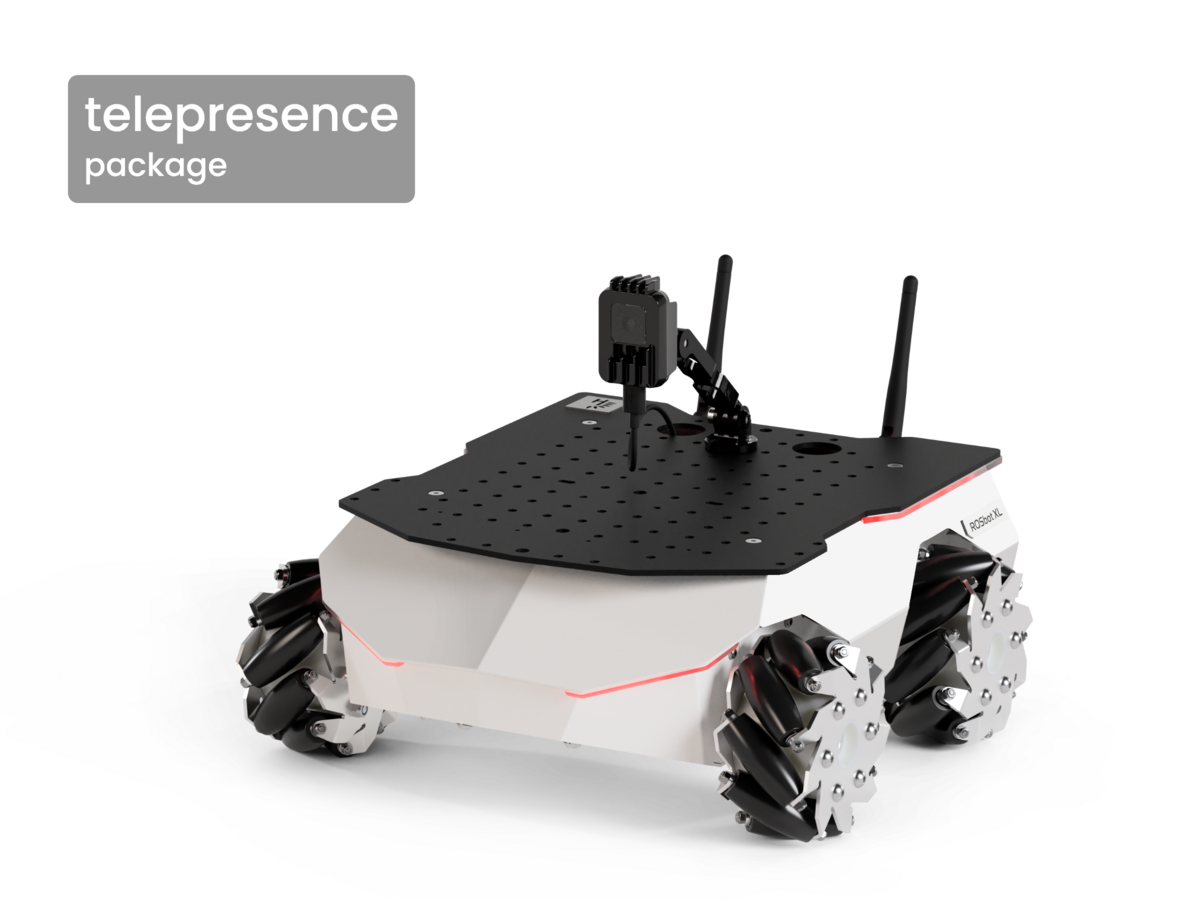
Select this package if you are planning to manually control ROSbot XL in two different scenarios: over web user interface or from RViz. Both setups work not only in LAN but also over the Internet.
Included SBC
| Name | CPU architecture | CPU | RAM | GPU | Storage |
|---|---|---|---|---|---|
| ASUS NUC (NUC14RVKi3) | x86-64 | Intel Core 3 100U 6 x 4.7 GHz | 16 GB | Intel® UHD Graphics | 250 GB SSD |
Additional Equipment
- Luxonis OAK-1 Lite camera
- USB 3.0 type C cable for OAK-1 Lite camera
- Camera holder
- Logitech F710 gamepad
Autonomy Package
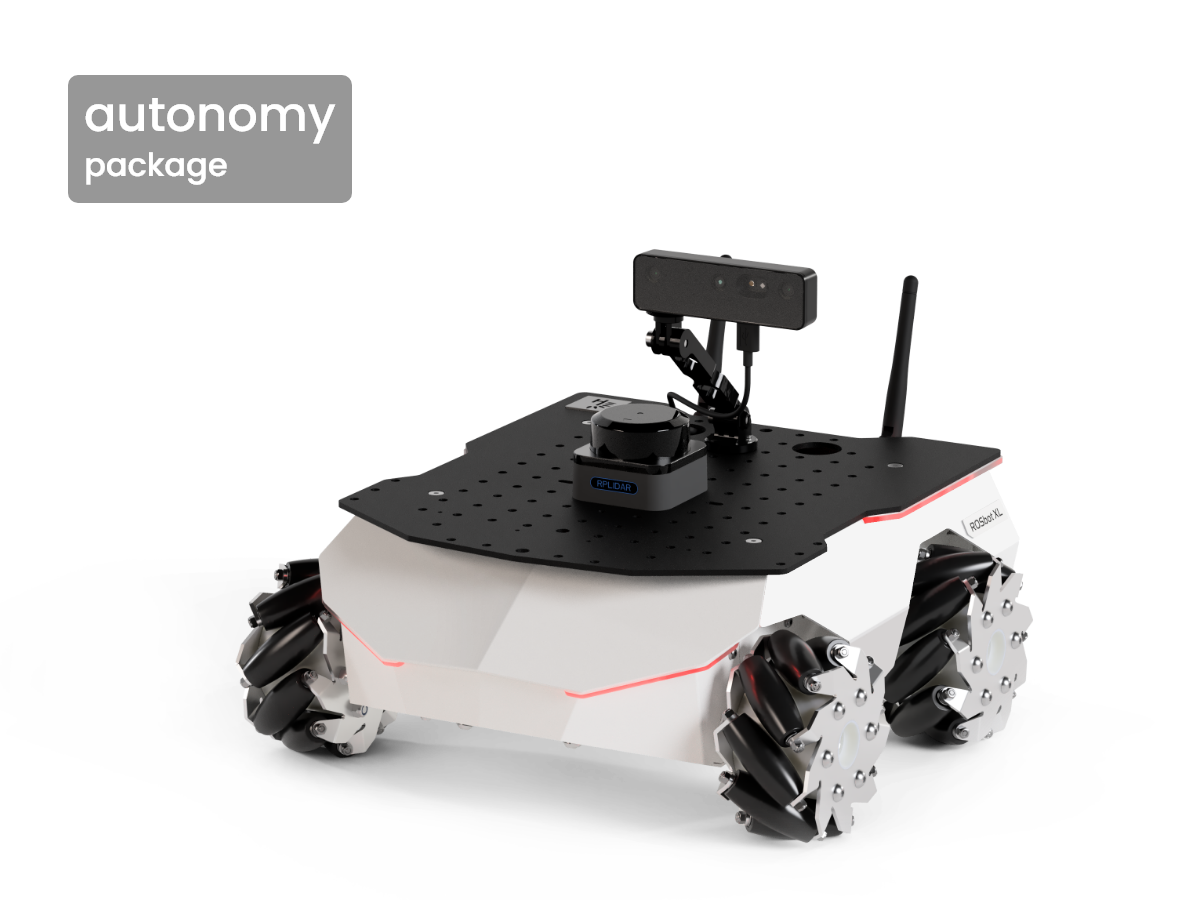
Select this package if you are planning to run autonomous mapping and navigation algorithms on your ROSbot XL.
Included SBC
| Name | CPU architecture | CPU | RAM | GPU | Storage |
|---|---|---|---|---|---|
| ASUS NUC (NUC14RVKi3) | x86-64 | Intel Core 3 100U 6 x 4.7 GHz | 16 GB | Intel® UHD Graphics | 250 GB SSD |
Additional Equipment
- SLAMTEC RPLIDAR S3
- Luxonis OAK-D Pro camera
- USB 3.0 type C cable for OAK-D Pro camera
- Camera holder
- Logitech F710 gamepad
Assembly Guide ⚙️
The LiDAR and the camera have to be assembled to the robot before use. Please follow the assembly guide.
Manipulation Package
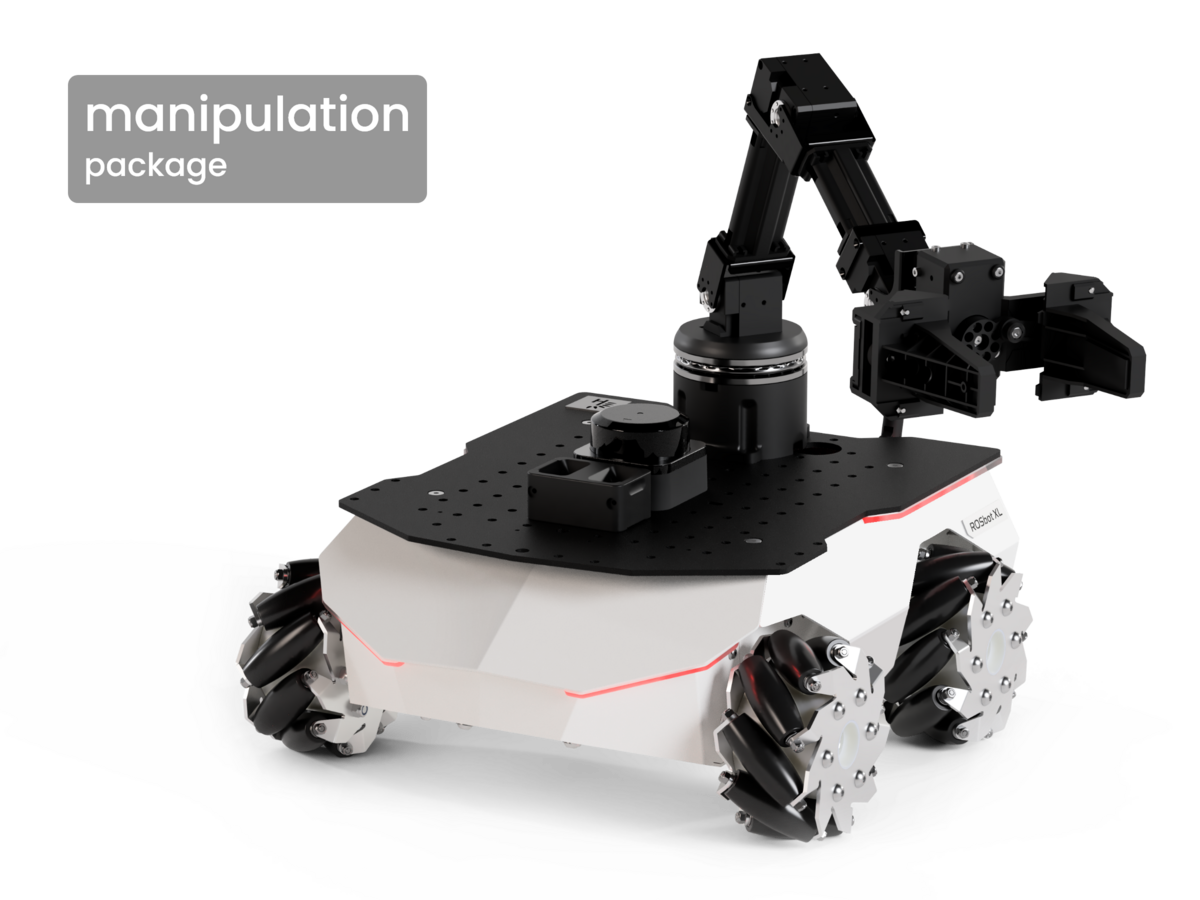
Select this package if you are planning to perform mobile manipulation tasks which include autonomous navigation.
Included SBC
| Name | CPU architecture | CPU | RAM | GPU | Storage |
|---|---|---|---|---|---|
| ASUS NUC (NUC14RVKi3) | x86-64 | Intel Core 3 100U 6 x 4.7 GHz | 16 GB | Intel® UHD Graphics | 250 GB SSD |
Additional Equipment
- SLAMTEC RPLIDAR S3
- OpenMANIPULATOR-X manipulator with a gripper by Robotis
- Control board for the manipulator
- Manipulator holder with a bearing
- Logitech F710 gamepad
Assembly Guide ⚙️
The LiDAR and the manipulator have to be assembled to the robot before use. Please follow the assembly guide.
Manipulation PRO Package
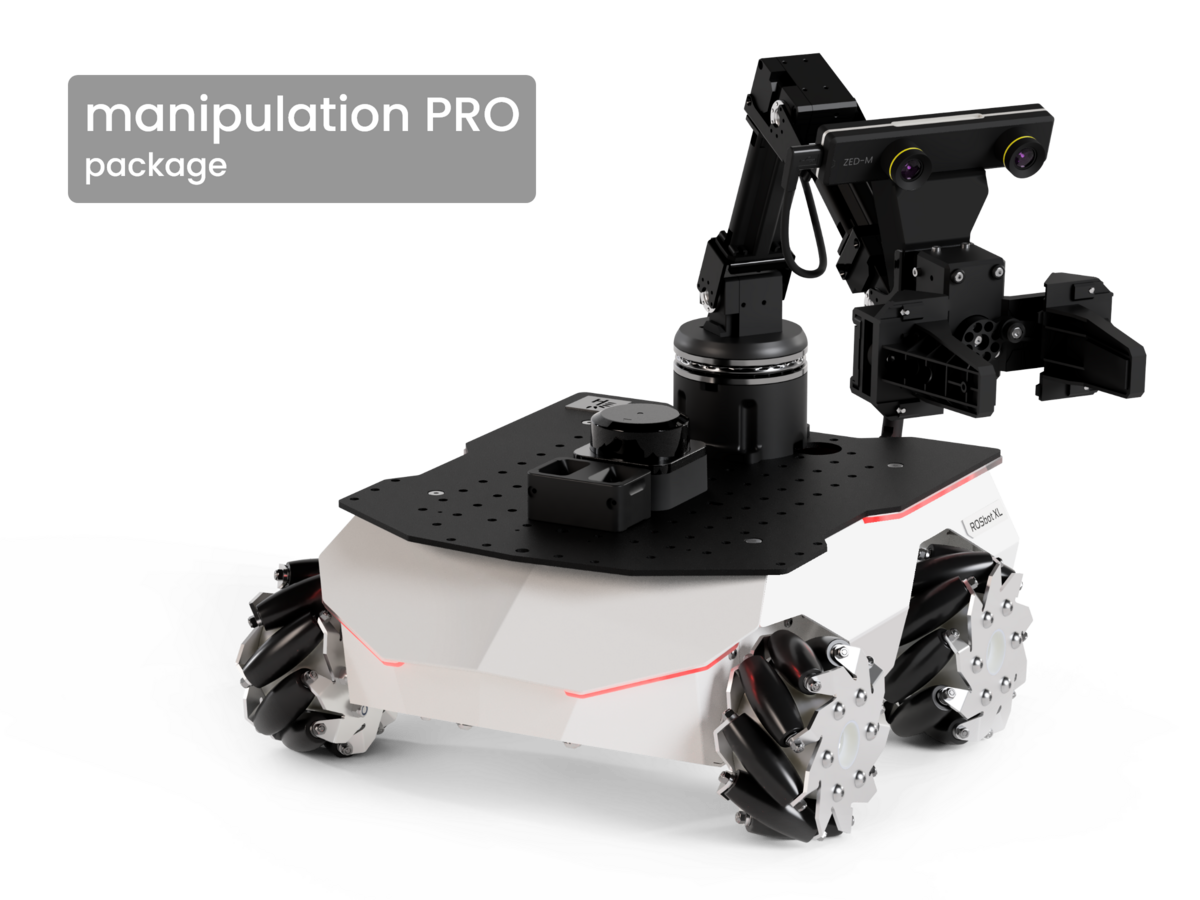
Select this package if you are planning to perform mobile manipulation tasks which include autonomous navigation and advanced vision capabilities (object recognition and handling).
Included SBC
| Name | CPU architecture | CPU | RAM | GPU | Storage |
|---|---|---|---|---|---|
| NVIDIA Jetson Orin Nano | ARM64 | ARM Cortex-A78AE 6 x 1.5 GHz | 8 GB | Nvidia Ampere 1024 CUDA cores 32 Tensor cores | 250 GB SSD |
Additional Equipment
- SLAMTEC RPLIDAR S3
- OpenMANIPULATOR-X manipulator with a gripper by Robotis
- Control board for the manipulator
- Manipulator holder with a bearing
- Stereolabs ZED Mini Stereo Camera
- USB cable for the camera
- Logitech F710 gamepad
Assembly Guide ⚙️
The LiDAR, the camera and the manipulator have to be assembled to the robot before use. Please follow the assembly guide.
Use cases
| Package | LiDAR | Camera | Manipulator | Teleoperation with a camera view | Mapping and navigation (Nav2) |
|---|---|---|---|---|---|
| Basic | – | – | – | – | – |
| Telepresence | – | OAK-1 Lite | – | ✅ | – |
| Autonomy | RPLIDAR S3 | OAK-D Pro | – | ✅ | ✅ |
| Manipulation | RPLIDAR S3 | – | OpenMANIPULATOR-X | – | ✅ |
| Manipulation PRO | RPLIDAR S3 | ZED Mini | OpenMANIPULATOR-X | ✅ | ✅ |
Every package includes a Logitech F710 gamepad, and the robot can always be driven from Husarion Cockpit; a camera adds the live video feed.
Everything below runs on the preinstalled Husarion OS: no extra repositories to clone or build.
Teleoperation with a camera view
Drive the robot from a phone or laptop in the Operate tab of Husarion Cockpit, with a live camera feed, an on-screen joystick and battery status. Open http://rosbot-<SERIAL_NUMBER>.local in a browser on the same network.
Requires a camera: Telepresence, Autonomy or Manipulation PRO package.
Autonomous mapping and navigation (Nav2)
Nav2 and SLAM Toolbox are bundled in the rosbot snap. Start mapping and navigation, then send the robot to a point on the map:
sudo rosbot.navigation-start
sudo rosbot.navigation-goal <x> <y> [yaw]
Requires a LiDAR: Autonomy, Manipulation or Manipulation PRO package.